IN Brief:
- A surveying drone struck a construction crane in Manchester during an automated flight in August 2026.
- The aircraft fell approximately 120 metres despite having its obstacle avoidance function enabled.
- The construction company's internal investigation identified possible shortcomings in understanding the system's limitations.
A surveying drone collided with the upper structure of a crane on a Manchester construction site despite having its obstacle avoidance function enabled, according to an incident record published by the Air Accidents Investigation Branch on 12 November 2026.
The collision occurred in August at a site in the Cheetham Hill area, where the unmanned aircraft was conducting an aerial survey using a preselected flight path. After striking the crane, the aircraft fell approximately 120 metres to the ground.
The Air Accidents Investigation Branch (AAIB) classified the occurrence as record only, meaning it did not undertake a full formal investigation. The construction company and individual site have not been publicly identified, while the aircraft’s manufacturer and model have not been disclosed.
An internal investigation by the construction company identified that the organisation and its remote pilots may not have fully understood the limitations of the aircraft’s obstacle avoidance software. The finding does not establish a definitive technical cause, but it identifies the operation and understanding of automated protective functions as areas requiring attention.
Aerial surveying is increasingly used on construction sites to capture progress photographs, support topographical assessment, and produce spatial information that can be integrated with digital project records. Repeated flights over the same area allow project teams to document changes between survey dates and maintain a consistent visual record of construction activity.
Preprogrammed flight paths can improve the repeatability of these surveys. By following defined routes and capturing images at planned intervals, an aircraft can collect material suitable for photogrammetric processing, where overlapping photographs are used to produce maps, surface models, and three-dimensional representations of the site.
The benefits of repeatable flight paths depend on those routes remaining suitable for the conditions encountered during each operation. Construction sites change as structures rise, temporary works are installed, equipment is relocated, and new activities begin. An area that was clear during an earlier survey may subsequently contain obstructions extending above the surrounding buildings.
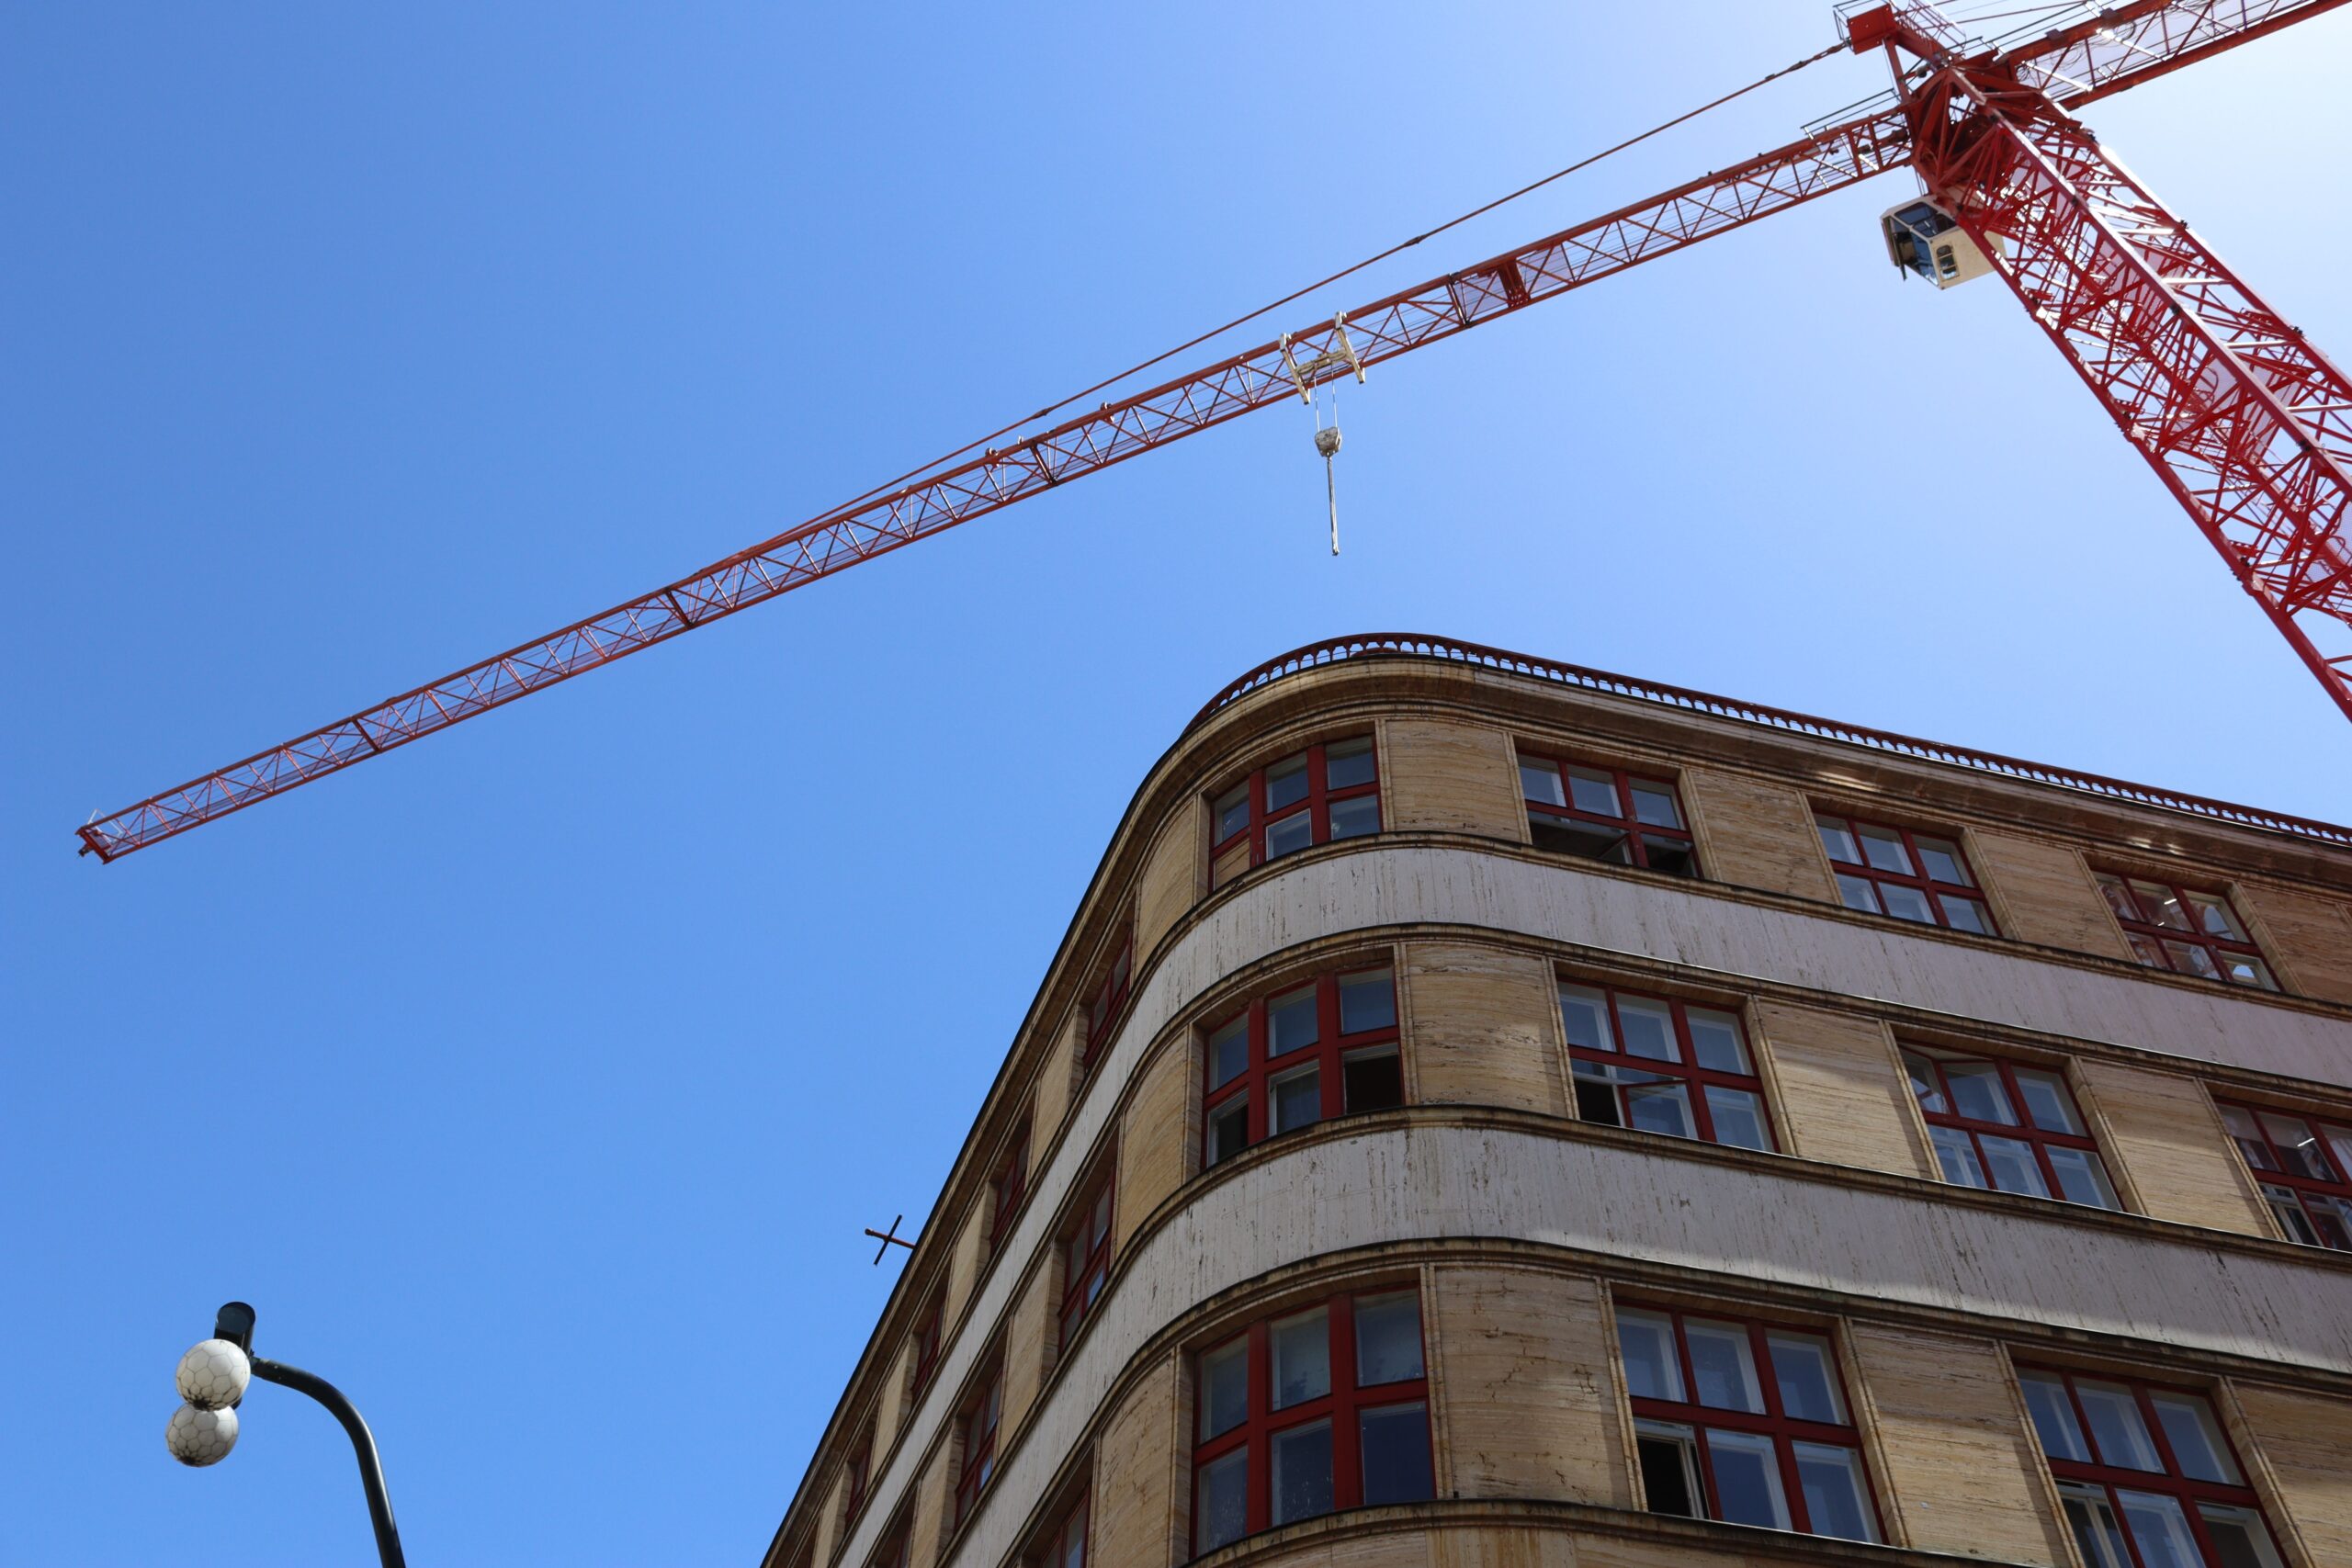
Tower cranes create a particular challenge because their jibs and associated structures can extend considerable distances from the main tower. The operating position of lifting equipment, together with the installation or removal of temporary structures, can alter the available flight space without substantially changing the ground-level layout.
The Manchester record does not establish the configuration of the crane, whether it was moving, or how its position related to the drone’s planned flight path. The confirmed circumstances are that the aircraft was carrying out an aerial survey, obstacle avoidance was enabled, and the aircraft nevertheless struck the top of the crane.
Obstacle avoidance functions are designed to assist a drone in detecting and responding to objects around it. Their effectiveness depends on the aircraft’s particular sensor arrangement, its operating mode, and the conditions in which those sensors are used.
Different systems may employ optical cameras, infrared sensors, ultrasonic measurement, or other technologies to detect nearby objects. Their capabilities vary, and detection performance can be affected by the size, shape, orientation, and surface characteristics of an obstruction, as well as lighting and environmental conditions.
Narrow structural members and complex equipment arrangements can present difficult detection conditions for some systems. However, the Manchester drone’s model and sensor specifications have not been identified, so it would be premature to attribute the collision to a particular sensing limitation or failure mechanism.
The aircraft’s automated flight capability introduces another consideration. An autopilot may follow a route established before take-off, while obstacle avoidance operates according to the aircraft’s programmed behaviour and available sensor information. The relationship between these functions differs between systems and may also depend on the flight mode selected.
Understanding those interactions is important when planning work around construction equipment. A flight management system may be capable of detecting certain obstructions without necessarily providing the response an operator expects in every operating mode. The availability of an automated function does not remove the need to understand its published limitations.
UK Civil Aviation Authority guidance requires remote pilots to maintain appropriate awareness of surrounding hazards and operate their aircraft safely. The Drone and Model Aircraft Code emphasises the responsibility to avoid collisions and maintain sufficient awareness of the aircraft’s position and surrounding airspace.
For operations conducted under visual line of sight requirements, remote pilots must be able to observe the aircraft and assess its position relative to nearby hazards. CAA guidance recognises that tall obstacles can restrict the distance over which an aircraft can be monitored effectively, requiring operators to adjust their operating arrangements accordingly.
Some commercial surveying activities may take place under authorisations permitting operations beyond the standard Open category conditions. The operating category and authorisations applicable to the Manchester flight have not been published, and the AAIB record does not establish that the operator breached aviation regulations.
Drone surveying also requires coordination with the wider construction programme. Information about crane positions, lifting activities, temporary works, and restricted site areas can affect the selection of a safe flight route, particularly where the aircraft is operating above a congested urban development.
A construction site may contain several organisations undertaking separate operations. Crane movements can be controlled by lifting teams, while surveying may be arranged by a site management or specialist technology contractor. Changes to the working environment therefore need to be communicated between the relevant parties before a planned flight is undertaken.
Where repeat surveys use previously established routes, the suitability of those routes needs reassessment against current conditions. The continued use of a saved flight plan does not establish that the physical environment remains unchanged, even when the aircraft’s navigation and protective functions are operating as designed.
The potential consequences of an aircraft collision extend beyond the loss of surveying equipment. A drone falling from height may present a hazard to people, vehicles, and equipment beneath its flight path. The published Manchester account does not identify injuries or damage beyond the collision and subsequent fall, and no further consequences should be assumed.
The AAIB’s record only classification also limits the conclusions that can be drawn. The available material does not provide flight telemetry, sensor logs, a detailed reconstruction, or a formal determination of the cause. It records the occurrence and the construction company’s preliminary findings about possible shortcomings in operators’ understanding.
The incident provides a documented example of a surveying aircraft colliding with construction equipment while an automated protective function was enabled. The internal investigation identified a possible knowledge gap, while the absence of a full technical investigation leaves the precise failure sequence unresolved.